Contacts that match the task
Open handle loops, grasp contacts on the lid and appliance handles, overlapping pan floors and walls, and fruit and bread hulls derived from the visible geometry.
Native contacts, repeatable tasks and inspectable results. One Franka arm at a carefully arranged kitchen station.
A scripted controller uses privileged object poses and drives the robot through contact. Successful grasps require measured finger forces, a lift, release and stable placement. These results establish what this baseline achieves in simulation; they do not demonstrate learned-policy performance or real-world transfer.
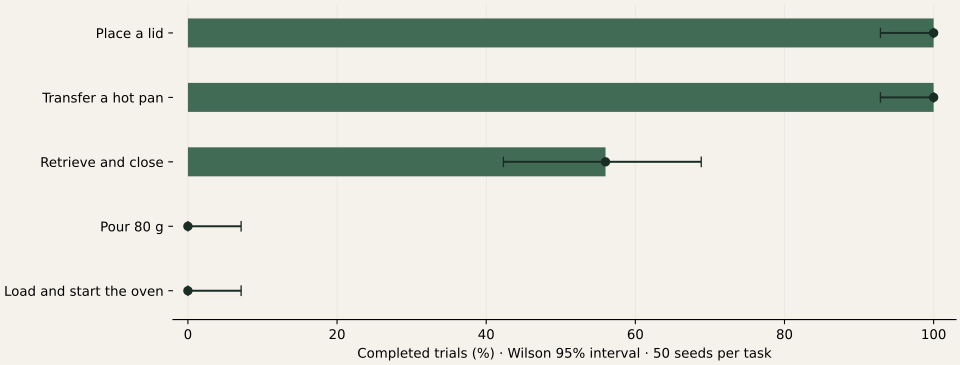
| Task | Completed | 95% interval | Simulator failures | Evidence |
|---|---|---|---|---|
| Place a lid | 50 / 50 | 92.9–100.0% | 0 | Run 1 |
| Transfer a hot pan | 50 / 50 | 92.9–100.0% | 0 | Run 1 |
| Retrieve and close | 28 / 50 | 42.3–68.8% | 0 | Run 1 · Run 2 · Run 3 |
| Pour 80 g | 0 / 50 | 0.0–7.1% | 0 | Run 1 · Run 2 · Run 3 |
| Load and start the oven | 0 / 50 | 0.0–7.1% | 0 | Run 1 |
The denominator includes simulator failures. A task with zero completions has not demonstrated feasibility with this controller. Read the failure records before using a setup for training.
Complete results · JSON · Trial index · CSV · Protocol, seeds and action interface
Fixed and wrist RGB-D, with seeded noise, missing depth and 80 ms delivery latency. Evaluator depth and instance labels are saved separately, aligned to the same capture timestamp.
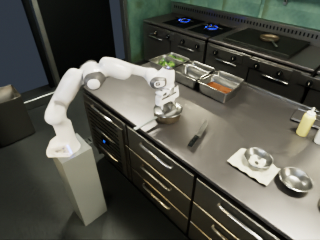
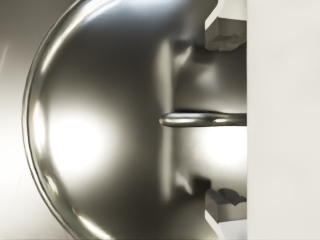
Camera calibration and timing · Fixed depth array · Wrist depth array
The separate camera demonstration took 150.0 wall-clock seconds, including startup, for 13.95 simulated seconds on an NVIDIA A10. Camera trial receipt · Evaluation protocol and source snapshots
The audit covers all 36 dynamic bodies, 114 fixed props, 175 structural groups and 1,721 colliders. Native readback checks mass and physically valid inertia. Individual 4 cm release tests add a small horizontal disturbance: 33 of 33 free objects settled within the three-second probe.
Open handle loops, grasp contacts on the lid and appliance handles, overlapping pan floors and walls, and fruit and bread hulls derived from the visible geometry.
Physical constants are estimates. Food is rigid, tongs and bottles have simplified behavior, and decorative dressing is identified in the inventory. Flames are visual; heat runs through the explicit adapter.
The reduced pouring model updates vessel mass, center of mass, inertia and heat. It is separate from GPU particle tests and does not simulate arbitrary splashes, sloshing or wet contact friction.
| Object | Mass · kg | Colliders | Release probe |
|---|---|---|---|
| Interactive drawer 1 | 2.500 | 8 | Joint constrained |
| Interactive drawer 2 | 2.500 | 8 | Joint constrained |
| Plating plate 0 | 0.480 | 25 | Settled |
| Plating plate 1 | 0.480 | 25 | Settled |
| Plating plate 2 | 0.480 | 25 | Settled |
| Plating plate 3 | 0.480 | 25 | Settled |
| Service spoon | 0.035 | 1 | Settled |
| Mise bottle 0 | 0.380 | 2 | Settled |
| Mise bottle 1 | 0.380 | 2 | Settled |
| Mise bottle 2 | 0.380 | 2 | Settled |
| Mixing bowl | 0.260 | 25 | Settled |
| Prep bowl | 0.260 | 25 | Settled |
| Prep spoon | 0.035 | 1 | Settled |
| Prep tongs | 0.095 | 1 | Settled |
| Empty target pan 0 | 0.240 | 5 | Settled |
| Empty target pan 1 | 0.240 | 5 | Settled |
| Empty target pan 2 | 0.240 | 5 | Settled |
| Saute oil 0 | 0.380 | 2 | Settled |
| Saute oil 1 | 0.380 | 2 | Settled |
| Saute work pan | 0.650 | 26 | Settled |
| Counter sauce pan | 0.650 | 26 | Settled |
| Stockpot | 1.200 | 27 | Settled |
| Lemon 0 | 0.120 | 1 | Settled |
| Lemon 1 | 0.120 | 1 | Settled |
| Lemon 2 | 0.120 | 1 | Settled |
| Lemon 3 | 0.120 | 1 | Settled |
| Bread roll 0 | 0.070 | 1 | Settled |
| Bread roll 1 | 0.070 | 1 | Settled |
| Bread roll 2 | 0.070 | 1 | Settled |
| Burger lower bun | 0.042 | 1 | Settled |
| Burger patty and toppings | 0.160 | 1 | Settled |
| Burger top bun | 0.043 | 1 | Settled |
| Lemon half | 0.060 | 1 | Settled |
| Loose saucepan lid | 0.085 | 4 | Settled |
| Pour jug | 0.320 | 28 | Settled |
| Oven door | 2.000 | 2 | Joint constrained |
Complete scene inventory · Native object receipts · Corrections and limitations
Use the demonstrated tasks for the next policy comparison. Improve failed controllers and validate measured props before adding more simulation complexity. Calibration, deformable food, combustion and whole-kitchen humanoid movement remain further work.
Explore the full kitchen gallery ↗